Open Source Safe Cracking Robots
Demonstrates an open-source robotic rig built with Arduino and 3D-printed parts that measures internal wheel tolerances to crack combination fire safes in under an hour.
Summary
Low-Cost Physical Security Auditing
Mechanical combination safes are commonly deployed in commercial and residential settings under the assumption that non-destructive brute-force attacks require prohibitive amounts of time. Nathan Seidle demonstrates a low-cost, open-source automated safe-cracking robotic platform fabricated using off-the-shelf 3D-printed components, an Arduino microcontroller, and standard stepper motors totaling approximately two hundred dollars.
Measuring Internal Wheel Pack Tolerances
Instead of blindly attempting all possible numerical combinations across the three-wheel or four-wheel pack, the robot uses a motor coupled with an optical encoder to measure mechanical resistance and wheel contact points while the safe remains closed. By measuring subtle rotational discrepancies when the dial interacts with internal drive pins, the system can reliably isolate one of the combination digits, dramatically reducing the remaining mathematical search space.
Optimizing Dialing with Set Testing
Standard dialing methods require resetting the entire wheel pack between attempts, consuming valuable seconds per trial. Seidle introduces a specialized search algorithm called set testing that groups potential number combinations into continuous sweeps, minimizing unnecessary reverse revolutions and reducing total cracking time to under sixty minutes on standard fire-resistant safes.
Open Source Hardware and Attack Demos
The complete schematics, 3D models, and Arduino firmware are released open-source to allow physical security professionals and penetration testers to audit safe vulnerabilities. Live demonstrations illustrate the physical mounting mechanism using high-strength neodymium magnets, automated dial calibration, and the precise mechanical retraction of the locking bolt upon discovering the final combination.
Related talks

Main Track 1·27 min
$200 open source robot that cracks combination safes by measuring internal bits and set testing.

Main Stage·42 min
Mark Omo · James Rowley
Reverse engineers electronic gun safes and commercial digital vaults, demonstrating effortless physical and electromagnetic bypasses across leading brands.
Main Stage·40 min
Dennis Giese · braelynn
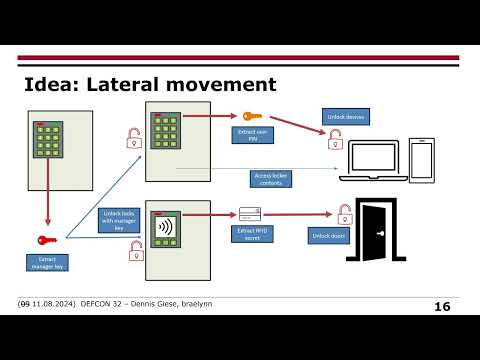
Security evaluation and hardware attack surface analysis of smart electronic lockers and storage cabinets.